Embodied AI · Robot Learning · Vision-Language-Action
Yushun Xiang 项裕顺
Master's student at RhOS lab, Shanghai Jiao Tong University, advised by Prof. Yong-Lu Li. I work on making robots that see, understand, and act, with a focus on efficient vision-language-action models and benchmarks for embodied agents.
News
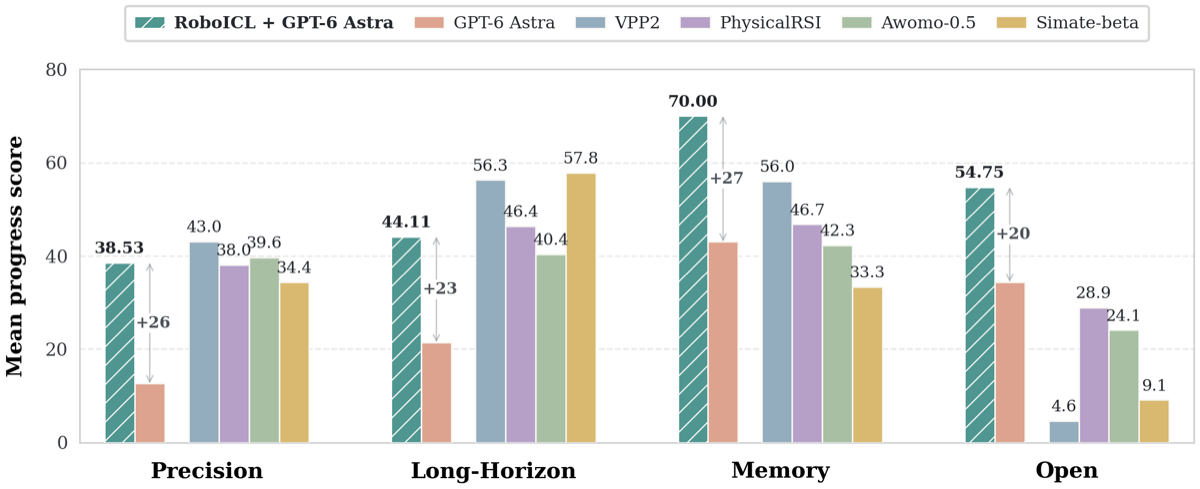
- RoboICL is out on arXiv: embodied in-context learning with GPT-6 Astra. Code and project page are available.
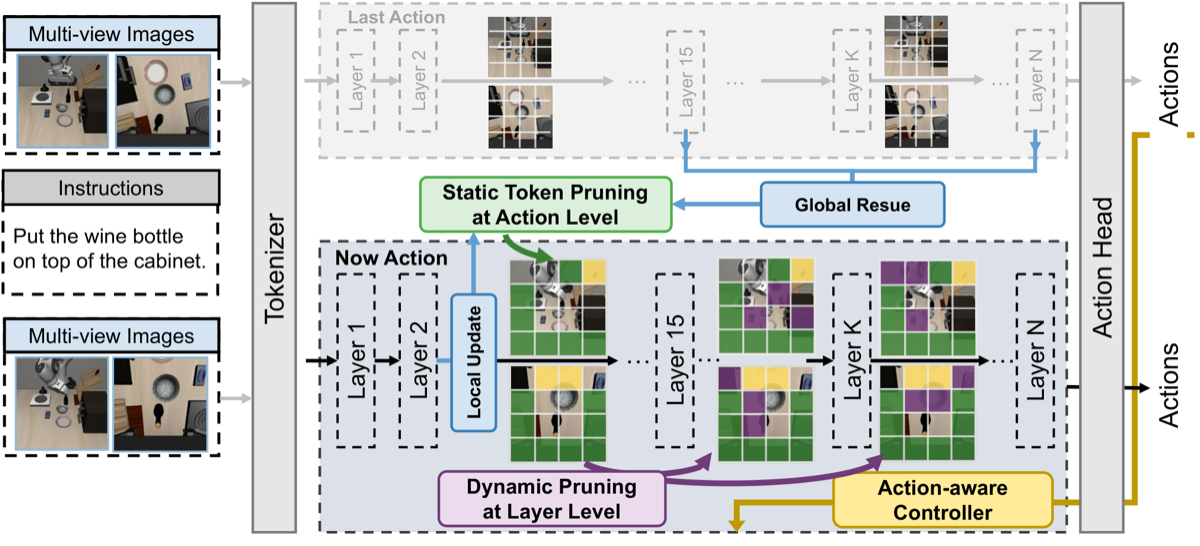
- SpecPrune-VLA was accepted to ICML 2026.
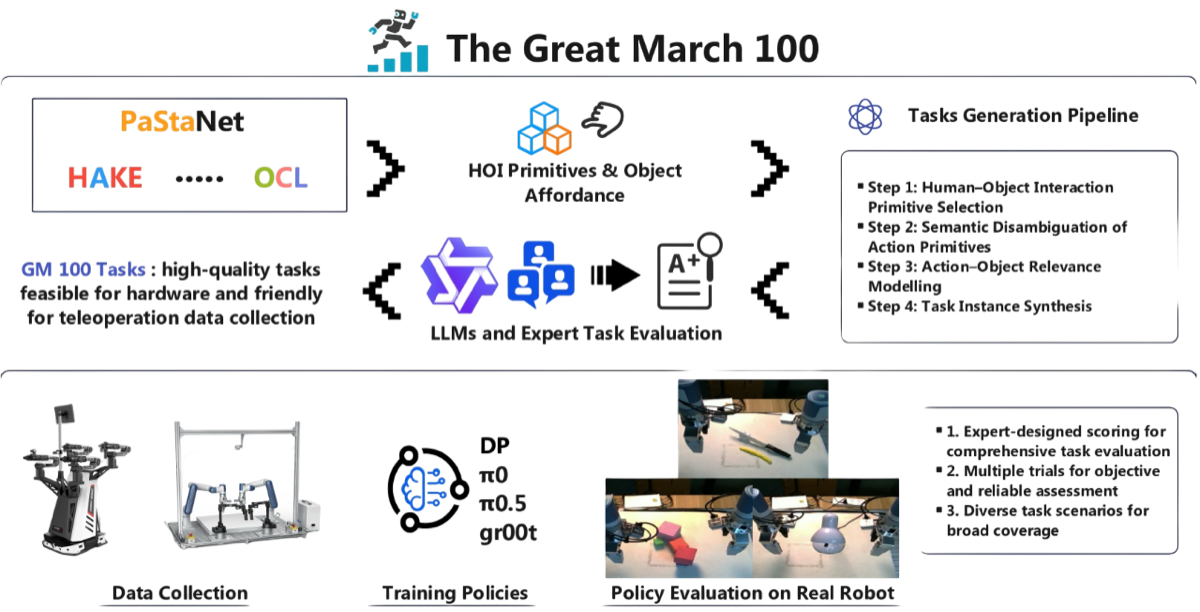
- We released The Great March 100 (GM-100), a benchmark of 100 detail-oriented tasks for embodied AI. See the project page.
- Started my master’s at RhOS, Shanghai Jiao Tong University.
Publications
* equal contribution
- Preprint 2026
RoboICL: Embodied In-Context Learning with GPT-6 Astra
arXiv preprint, 2026
Drives a frozen GPT-6 Astra as a few-shot robot learner using demonstration context and a bounded, anchored interaction memory, with no robot-specific training.
- Preprint 2026
The Great March 100: 100 Detail-oriented Tasks for Evaluating Embodied AI Agents
arXiv preprint, 2026
GM-100: a benchmark of 100 long-tail manipulation tasks built from human-object interaction primitives and object affordances, with large-scale teleoperation data, designed to separate today's VLA models.
- ICML 2026
SpecPrune-VLA: Accelerating Vision-Language-Action Models via Action-Aware Self-Speculative Pruning
International Conference on Machine Learning (ICML), 2026
A training-free, two-level token pruning scheme for VLA policies: action-level static pruning plus layer-level dynamic pruning, steered by an action-aware controller, for faster inference at near-identical success rates.
About
Honors & Awards
- Meritorious Winner, Mathematical Contest in Modeling
- Chinese National Scholarship
- Excellent Intern, a summer internship program organized by ASLP@NPU